> For the complete documentation index, see [llms.txt](https://docs.auterion.com/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://docs.auterion.com/hardware-integration/skynode/payloads/nextvision-nighthawk2-colibri2-with-trip2.md).
# NextVision Gimbals (TRIP2 / TRIP6)
{% hint style="info" %}
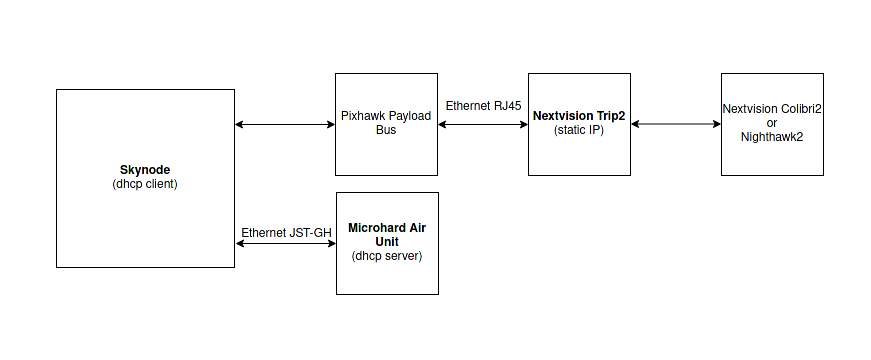
This section describes how to set up the Nextvision with Skynode. Please refer to[ this page](/hardware-integration/hardware-integration/initial-vehicle-wiring.md#pixhawk-payload-bus) for wiring instructions and [this page](/hardware-integration/skynode/peripherals/pixhawk-payload-bus.md) for specifics about the Pixhawk Payload Bus.
{% endhint %}
{% hint style="danger" %}
The officially supported gimbals are the NextVision:
* Raptor / Raptor 360
* NightHawk2 / NightHawk2-UZ
* Colibri2
* DragonEye2
* Starling
* X80
The officially supported computers are the NextVision TRIP2 and TRIP6.
Other gimbals and computers may work but might have missing features or unexpected behaviors.
{% endhint %}
## What you will need for this step
* One of the following:
* Skynode X with Pixhawk Payload Bus (connected as described in [Pixhawk Payload Bus](/hardware-integration/skynode/peripherals/pixhawk-payload-bus.md))
* Skynode S with Adapter Board and USB to Ethernet adapter
* Skynode N
* IP radio (for the data link to the ground station)
* JST-GH to Ethernet (RJ45) cable supplied with the TRIP
* A supported Nextvision gimbal
* Nextvision TRIP2 or TRIP6
## Preparation
To access the payload settings you need to connect the payload via Ethernet to your computer. The default IP address for Nextvision is 192.168.0.201. This means you need to assign a static IP address on your computer's Ethernet that is in the same subnetwork (eg. 192.168.0.10) as the Nextvision camera. The next section goes through some of the payload settings that we will change to be compatible with the Auterion setup. These include:
* The TRIP and Skynode must be on the same subnet. Skynode has no default Ethernet network, so it must be configured via `/data/override.env` (see [IP Settings](#ip-settings) and [Configure the Ethernet Network on Skynode](/hardware-integration/skynode/advanced-configuration/custom-data-link.md#configure-the-ethernet-network-on-skynode)). The addresses below (192.168.168.0/24) are only an example.
* The TRIP video output format (**Encapsulated Format** in the [Video Settings](#video-settings)) must be set to **MP2TS** instead of **RTP**, as expected by Skynode
* The default Skynode Nextvision protocol is **mavlink extended**
{% hint style="warning" %}
If you change the TRIP's IP address, change the **Network Settings** last. Once the TRIP moves to its new address, your computer can no longer reach it at 192.168.0.201 until you change your computer's IP to the new subnet.
{% endhint %}
### Network Settings
Example:
* IP address: 192.168.168.201
* Gateway: 192.168.168.1

### Video Settings
* Encapsulated Format: MP2TS over RTP
* Destination Port: 11024
* Disable Video Redirection
* Enable Stream IDR Mode
* Enable Roll Derotation setting is optional, it can also be changed from the camera settings in AMC

### Communication Settings
* Protocol Type: Mavlink Extension
* Protocol Medium: Ethernet
* Protocol Report Port: GCS Port
* Remote IP: Skynode's IP, e.g. 192.168.168.100 (must match, otherwise the gimbal will not respond in AMC)
* Remote Port: 10024
* Local Port: 10024

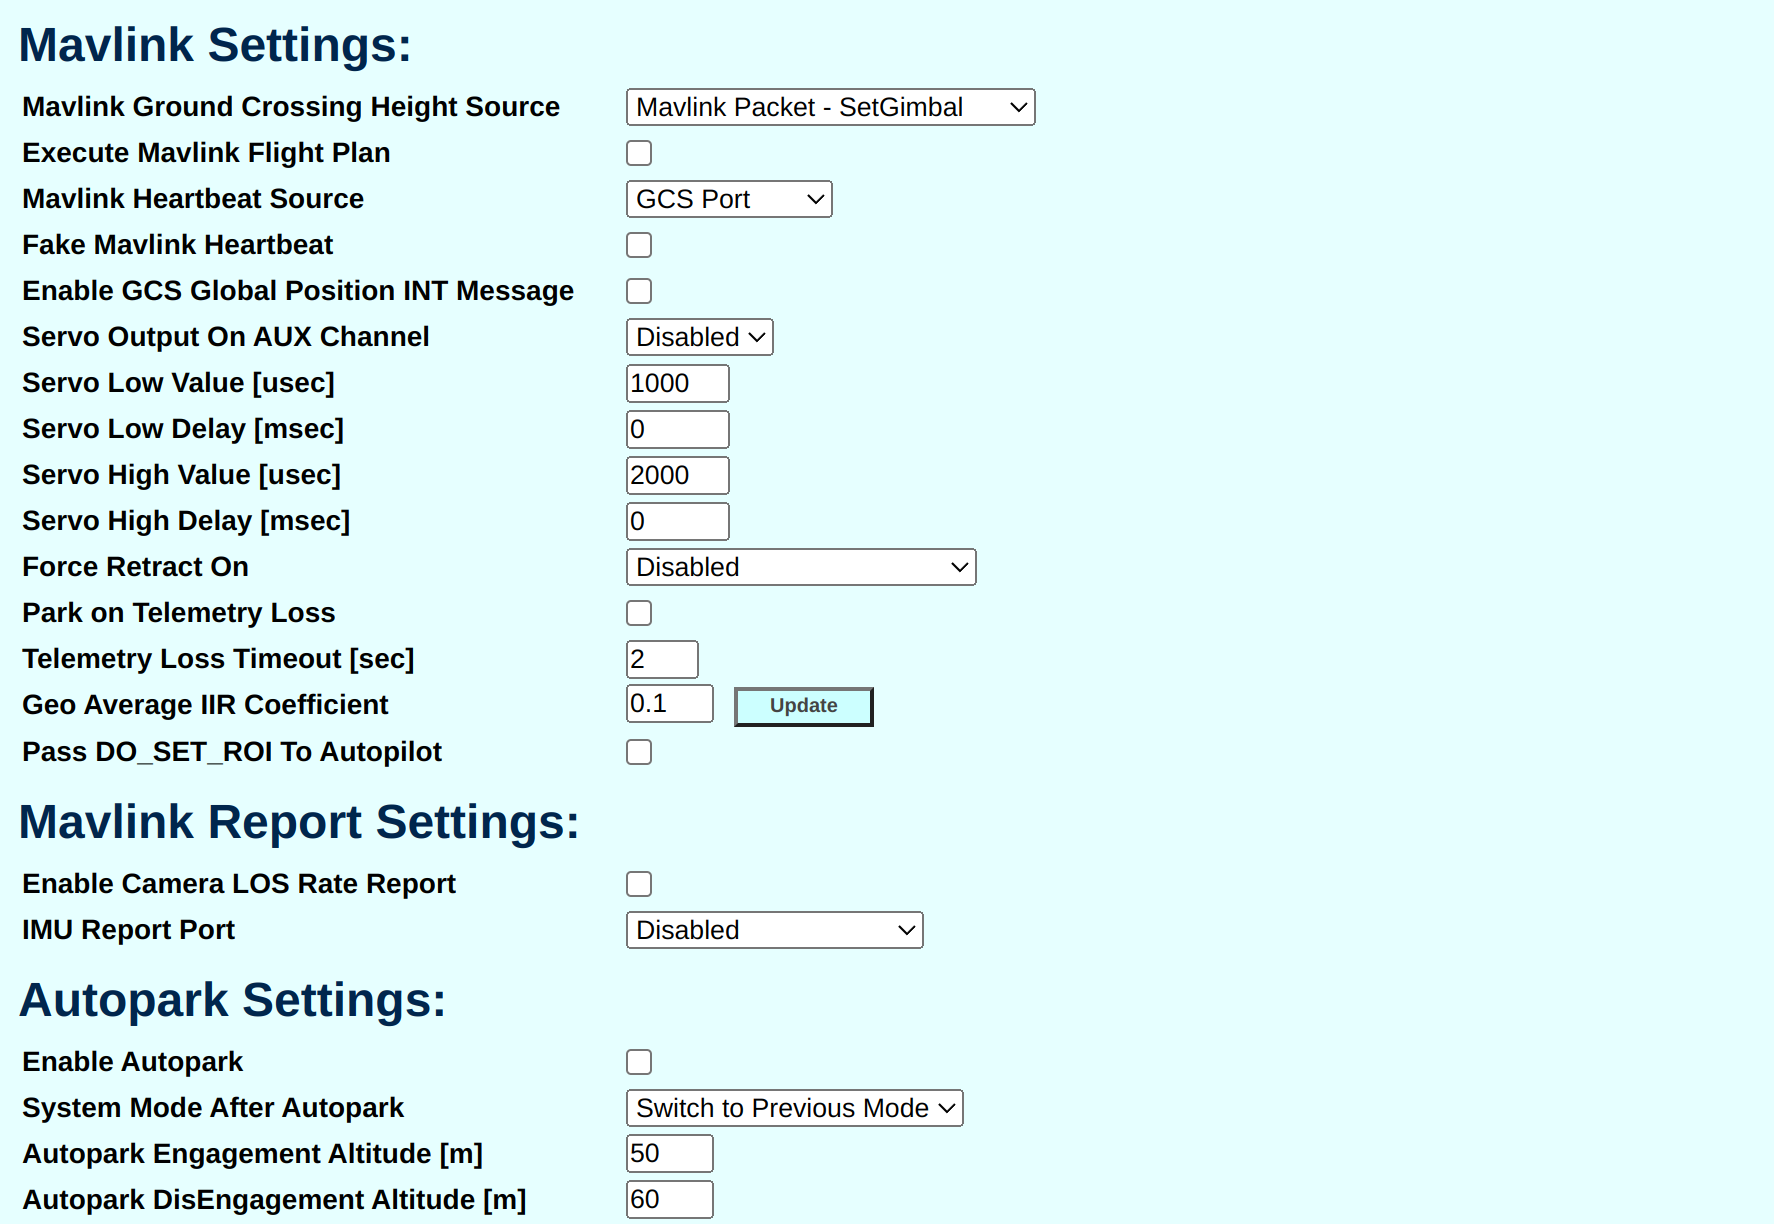
### Mavlink Settings
* Mavlink Ground Crossing Height Source: Mavlink Packet - SetGimbal
* Execute Mavlink Flight Plan: disabled
* Mavlink Heartbeat Source: GCS Port
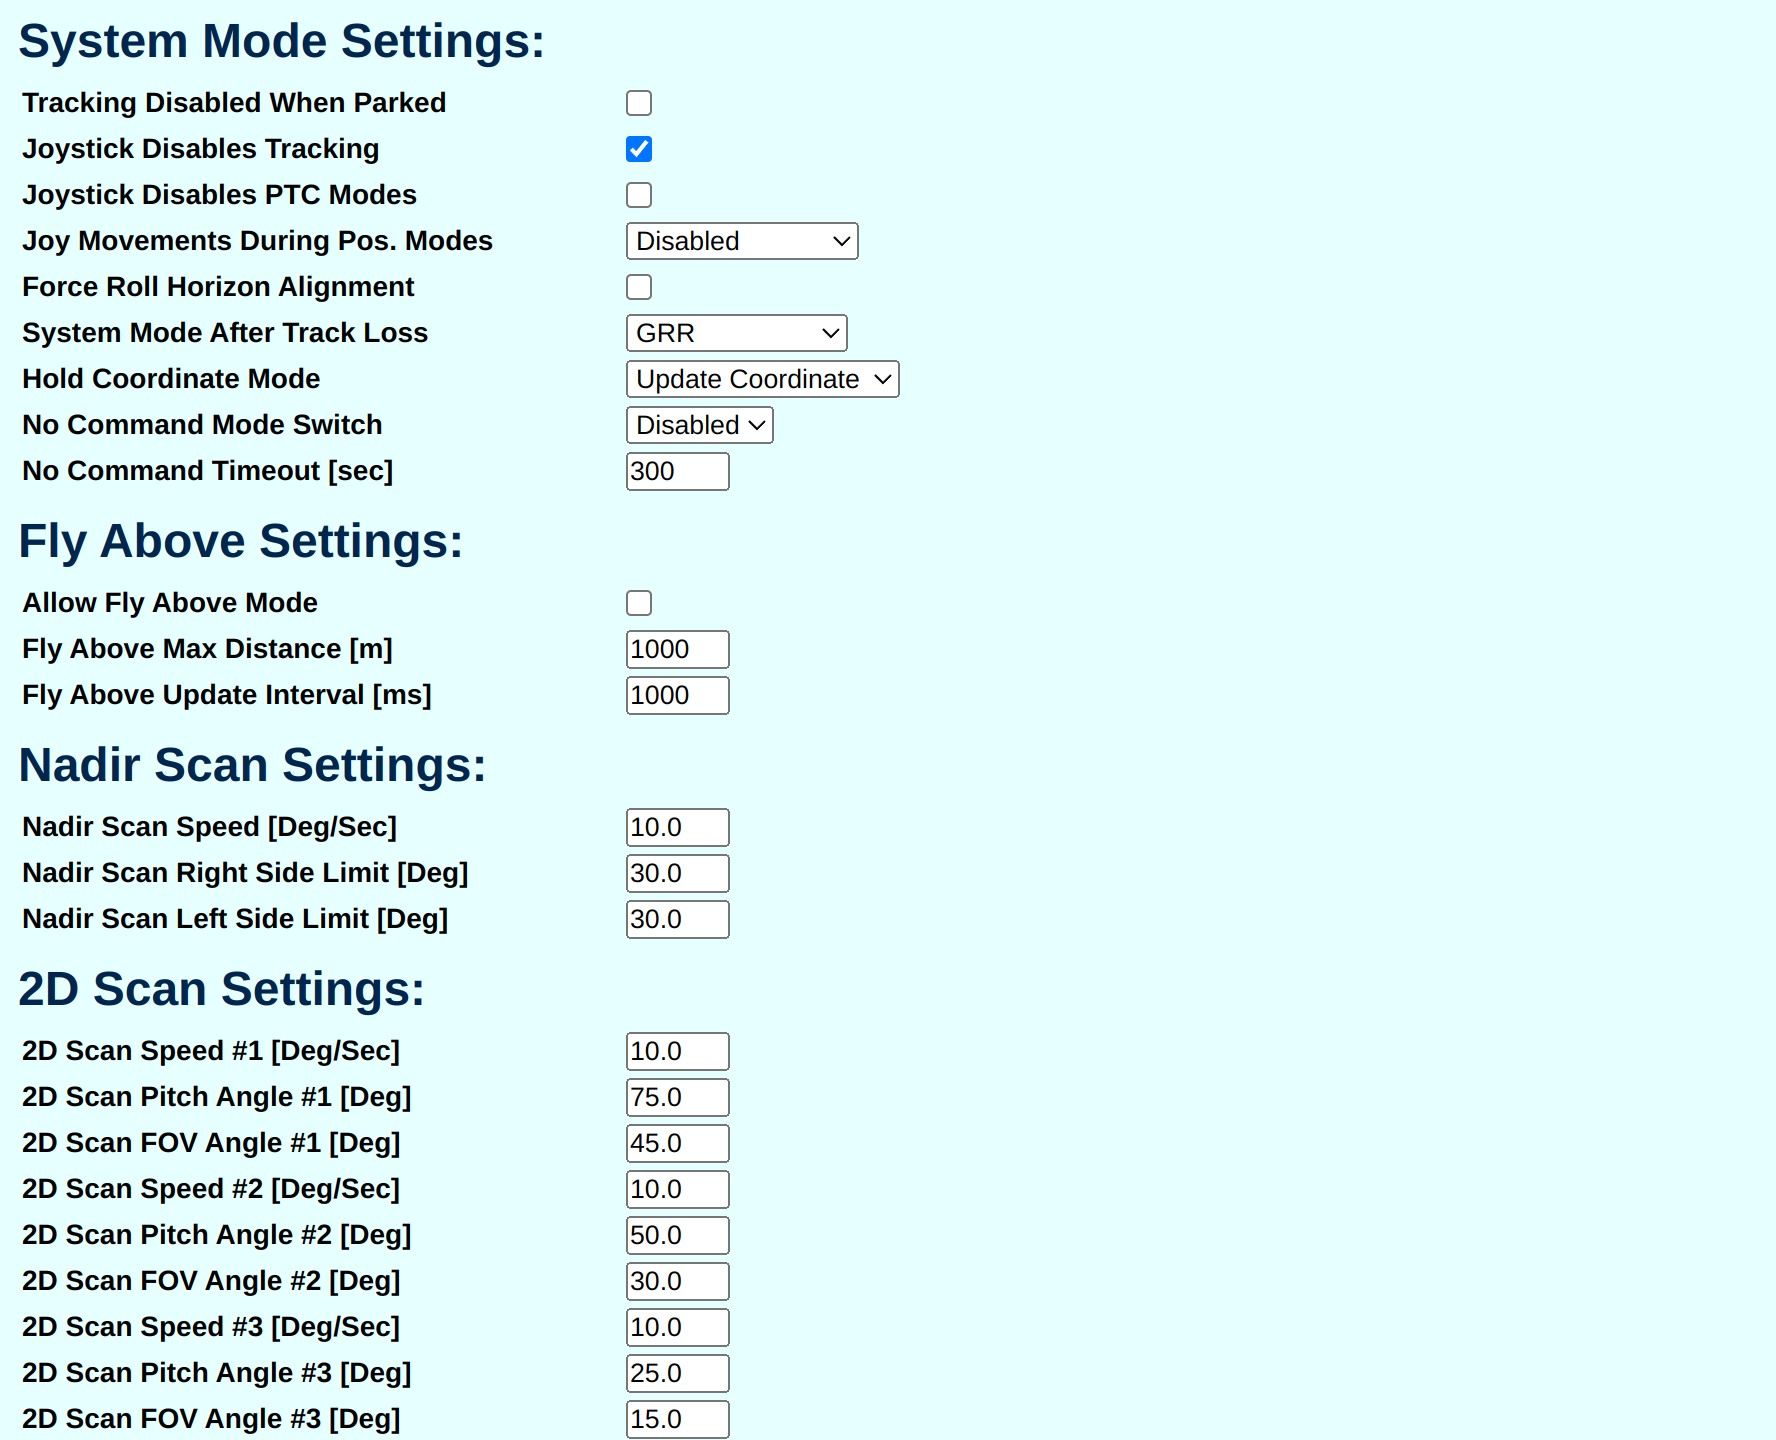
### System Mode Settings
* Joy Movements During Pos. Modes: Disabled
* System Mode After Track Loss: GRR (If a valid CFoV coordinate is available, a POI will be set on the last tracked location instead)
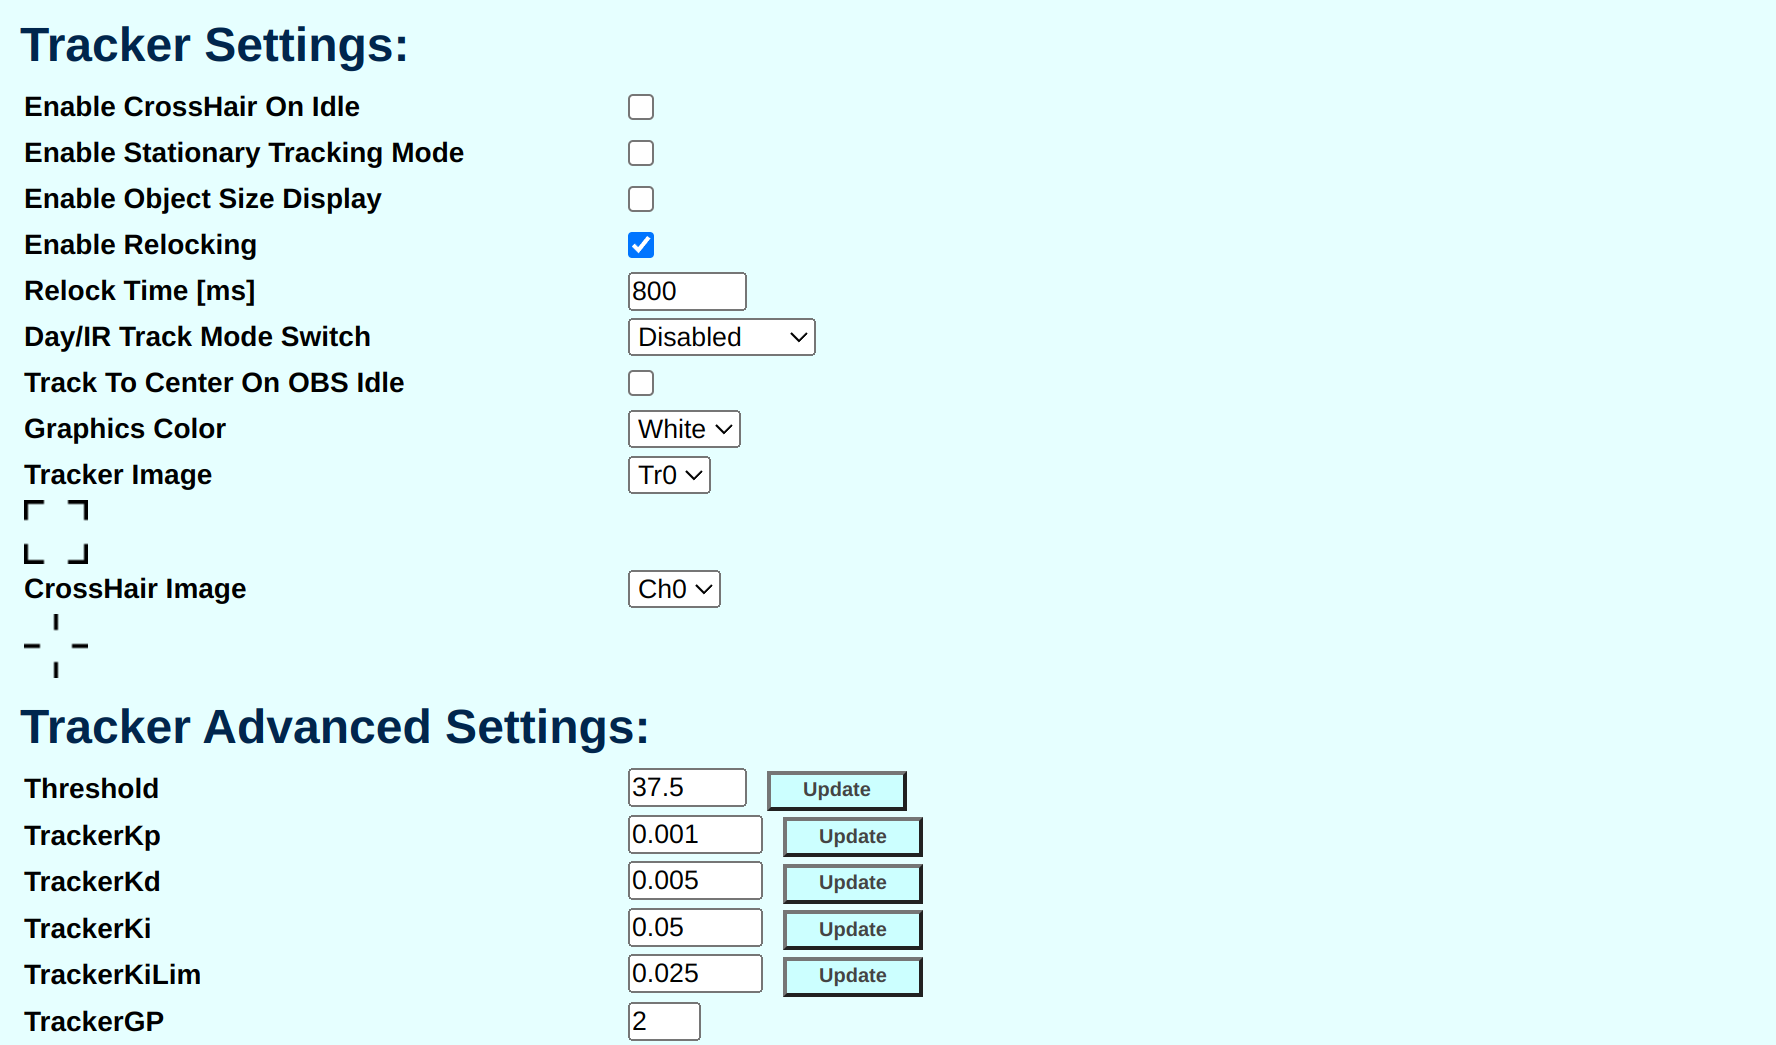
### Tracker Settings
* Enable Relocking (optional)
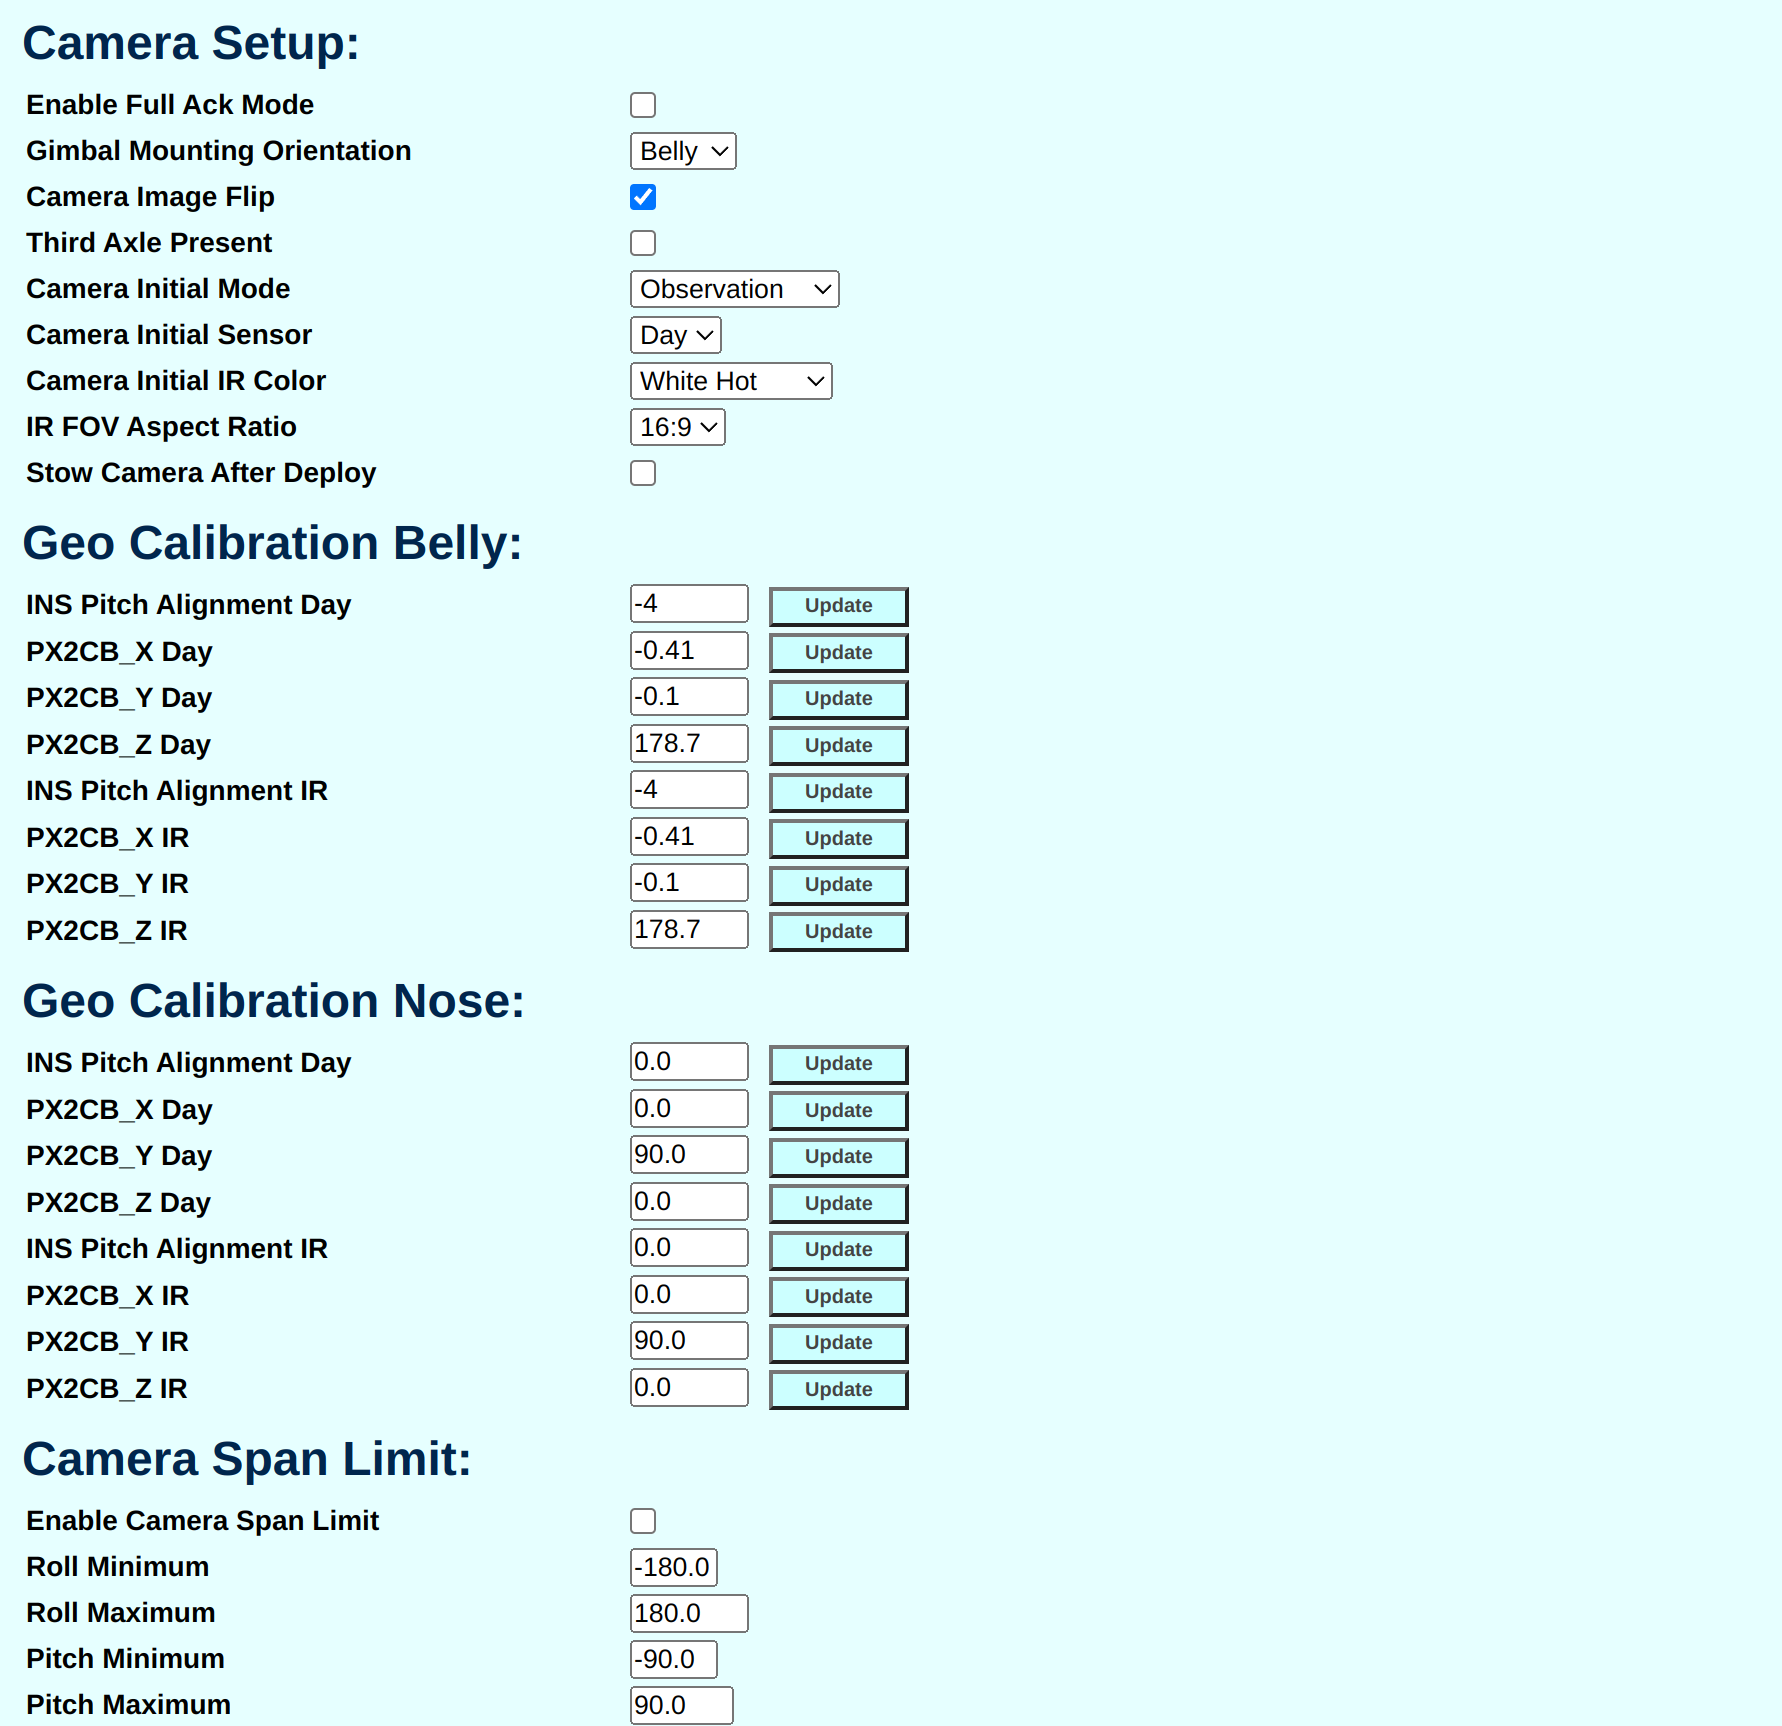
### Camera Settings
* Enable Full Ack Mode: disabled
* Camera Initial Mode: Observation
These camera settings need to be set according to the position of the gimbal in relation to the vehicle:
* Set to Belly or Nose according to vehicle
* Enable Camera Image Flip if necessary for vehicle
* Geo Calibrate according to vehicle, if there is a rotational offset between autopilot and gimbal a calibration is needed.
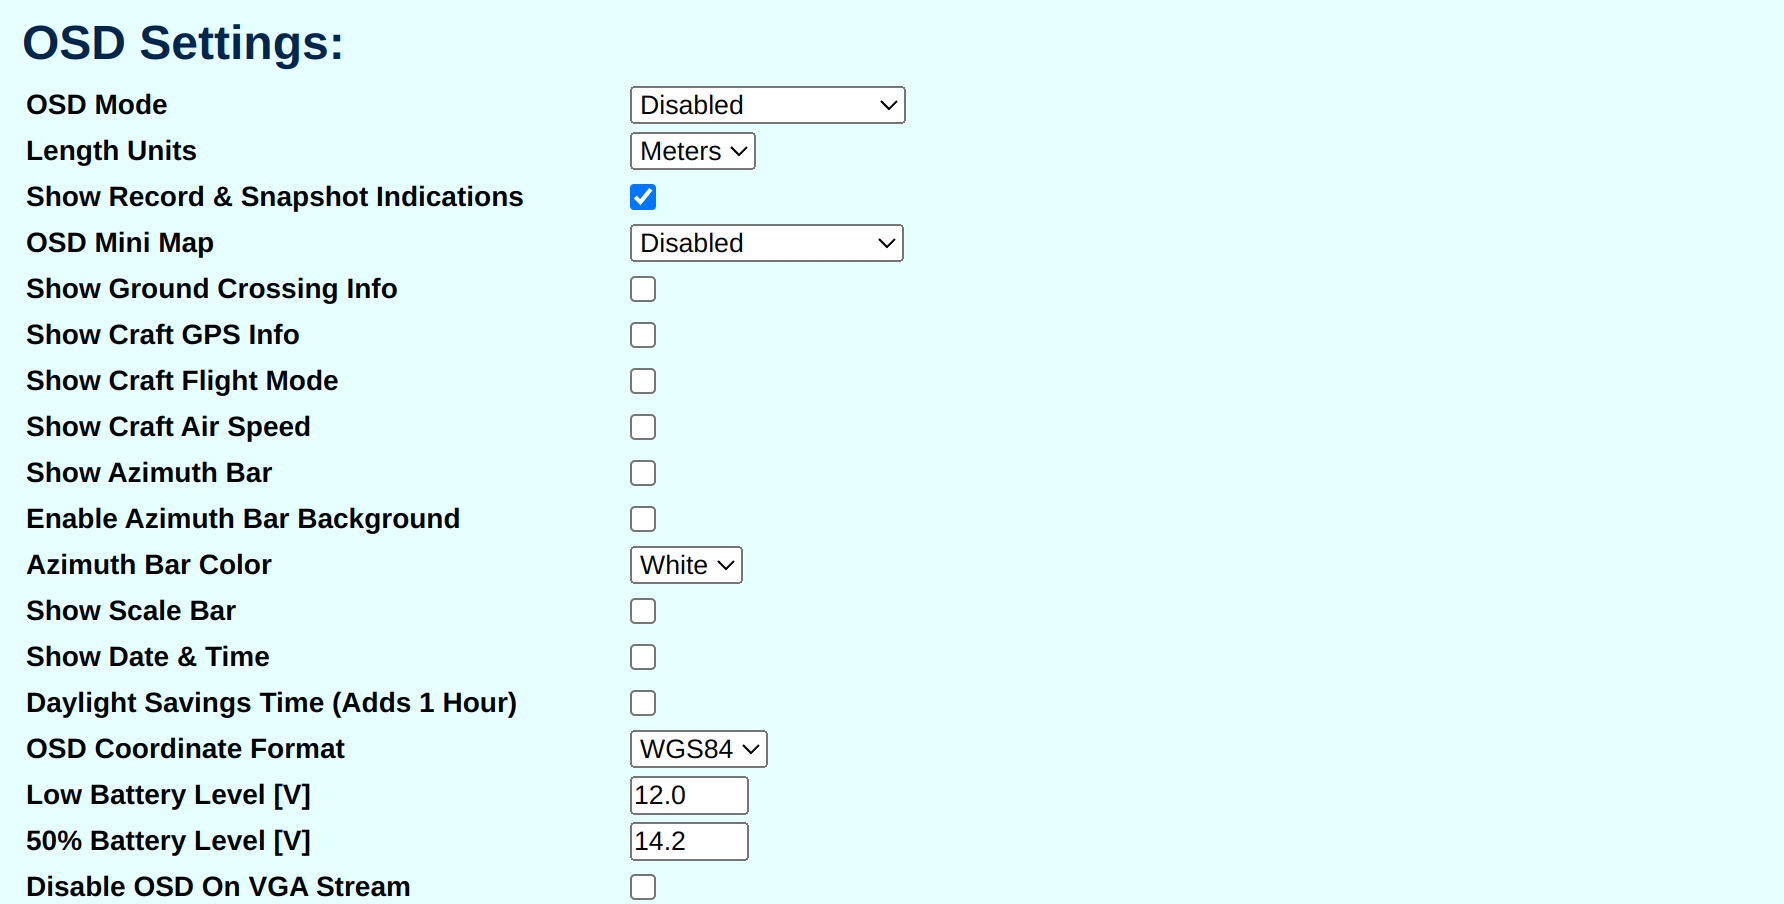
### OSD Settings
* OSD Mode: Disabled
* OSD Mini Map: Disabled
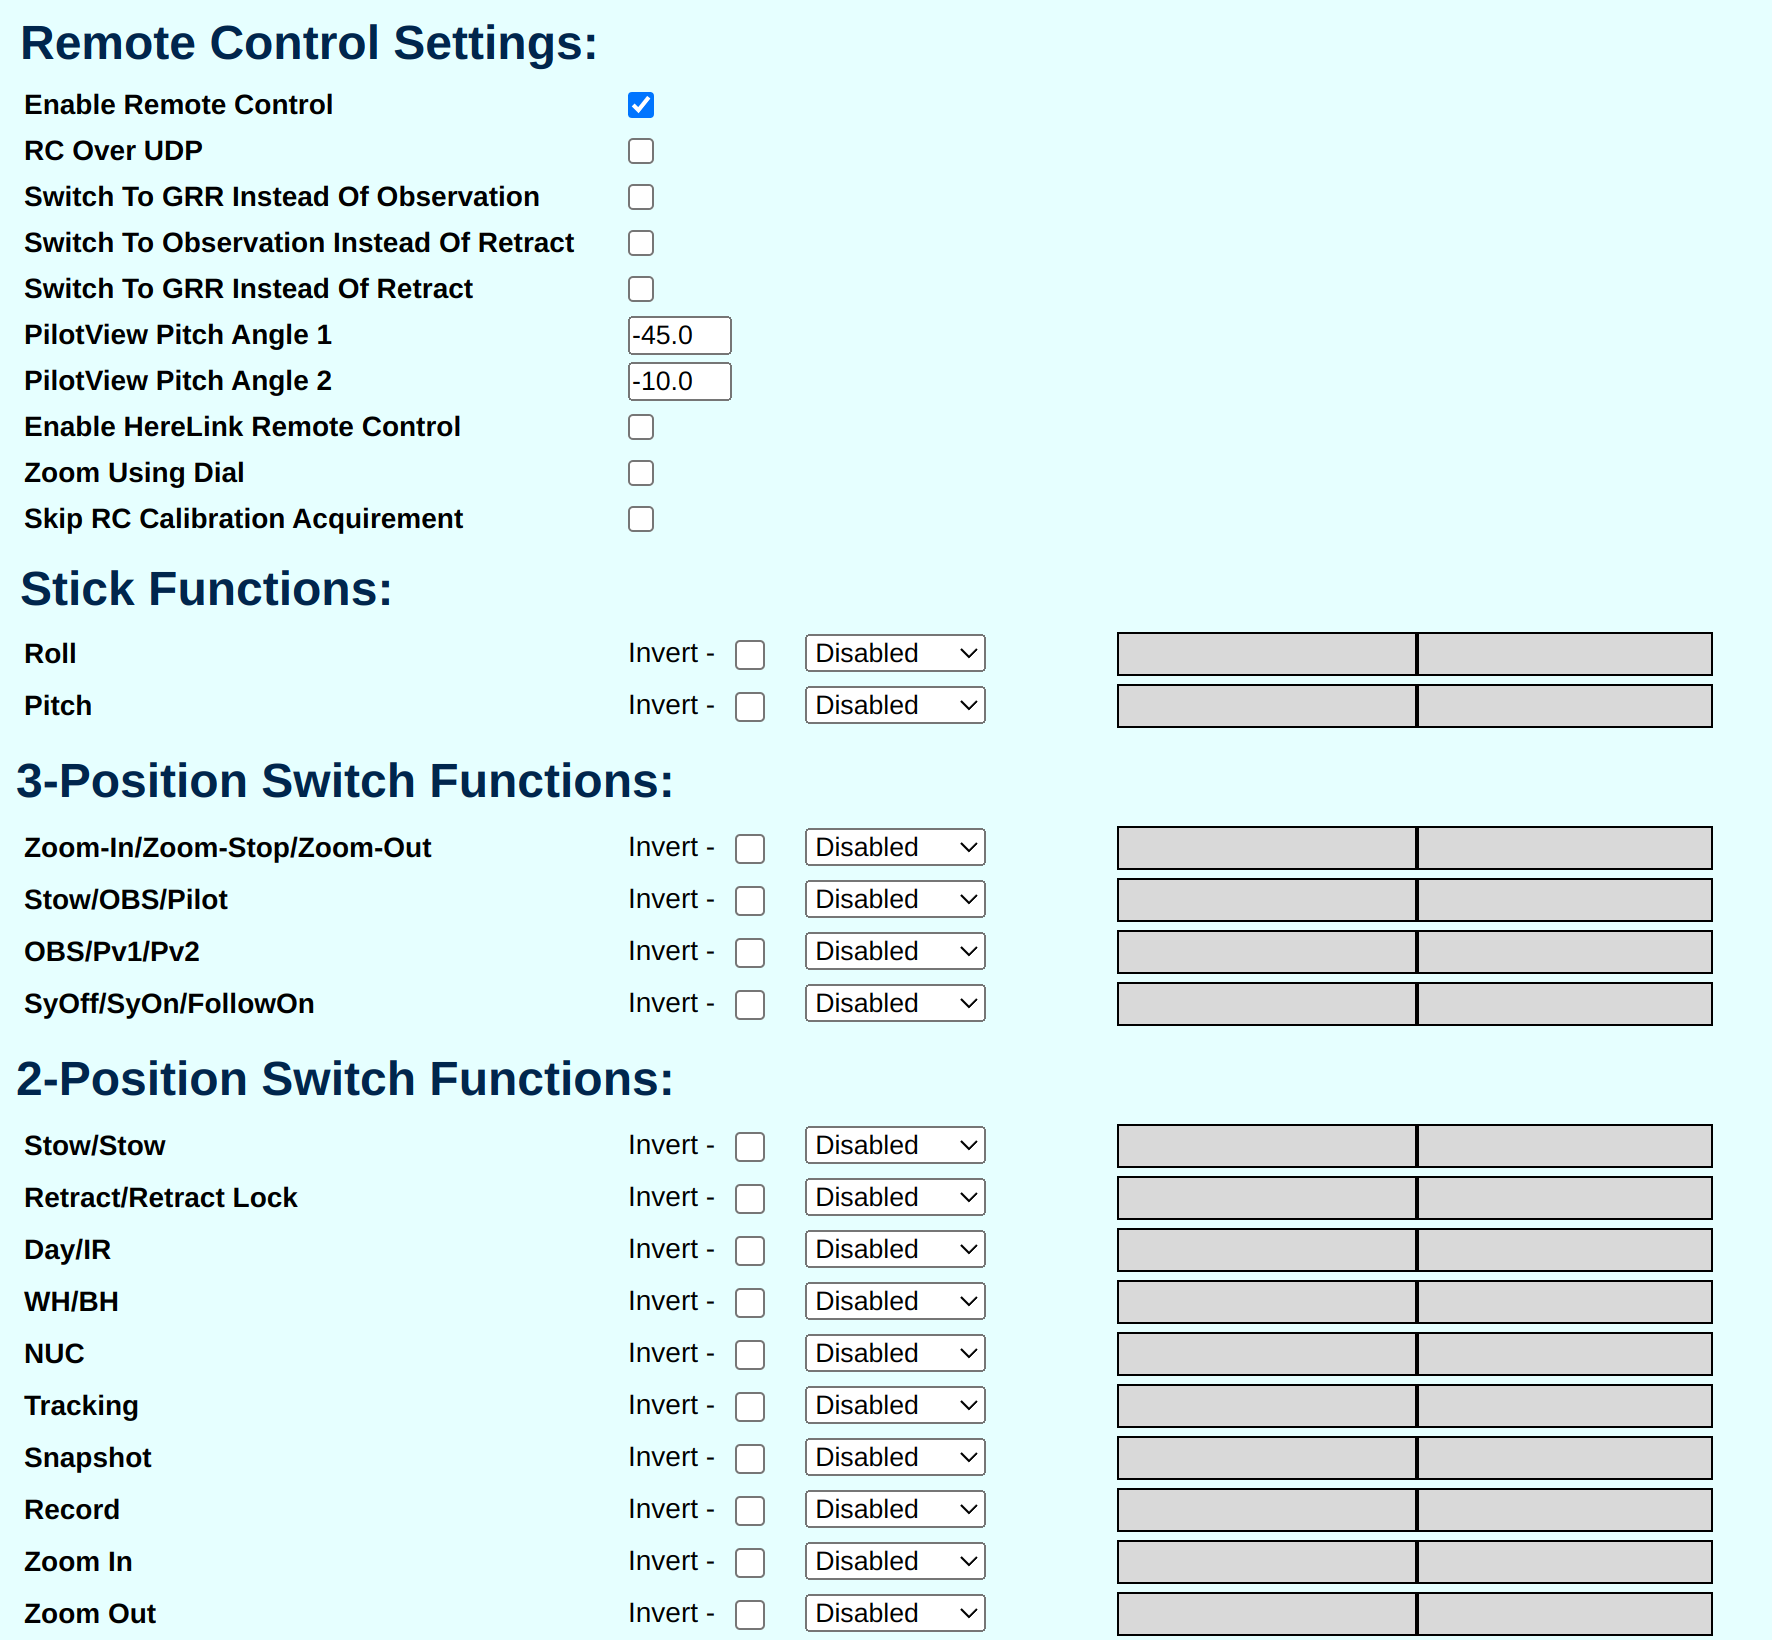
### RC Settings
Auterion Systems support the use of a RC to control the gimbal. If used:
* Enable Remote Control
* Select channels for the functions
## Setup
1. Connect the camera to the TRIP computer.
2. Connect the TRIP computer to the Pixhawk Payload Bus Adapter Board using the JST-GH to Ethernet RJ45 cable that is provided with the TRIP or directly to the Skynode Ethernet port if using Skynode N.
3. Follow the instructions in [General Setup](/hardware-integration/skynode/payloads.md#general-setup-same-for-all-payloads). This section is the same for all payloads.
### IP Settings
Set a static IP for Skynode matching the **Remote IP** configured on the TRIP, such as 192.168.168.100.
* Login into Skynode via [SSH](/hardware-integration/flight-controller-customization/flight-controller-shell.md#ssh-to-the-mission-computer)
* Create the file /data/override.env (if it already exists, append to it)
* Add the following environment variables, adapted to your network (`PAYLOAD_MNG_CTRL_IP_NV` is the TRIP's IP)
```
AP_CONFIGURE_ETHERNET_IP=192.168.168.100
PAYLOAD_MNG_CTRL_IP_NV=192.168.168.201
```
* Reboot Skynode
## Features
1. Tracking Mode: The gimbal follows the selected target
2. Point of Interest: The gimbal locks on a geo coodinate. It can be set by selecting the location on the map or on the video feed.
3. GRR: The system compensates for angular and translational movement of the platform. It will attempt to maintain the ground crossing location in the center of the image.
4. Observation: Similar to GRR, but the gimbal *does not* compensate for translational movement of the platform. For example: If the gimbal is looking north, and the vehicle turns, the gimbal will continue looking north.
5. UPOS: Gimbal remains in fixed position relative to the vehicle.
6. EO: Switch to electro-optical image sensor
7. IR: Switch to thermal image sensor
8. Switch between photo and video mode
9. Take a picture or start and stop recording a video
10. Open the settings
11. Zoom in
12. Zoom out
13. Current Field of View (changes with zoom)
14. Virtual Joystick, only shown if enabled in the settings
15. Current Angle of the gimbal
16. Cancel POI: Only shown if a POI is set
17. FPV: The gimbal points forward, aligned with the vehicle's heading
18. NADIR: The gimbal points straight down
19. Camera selection: Switch between the connected cameras
### Center Field of View
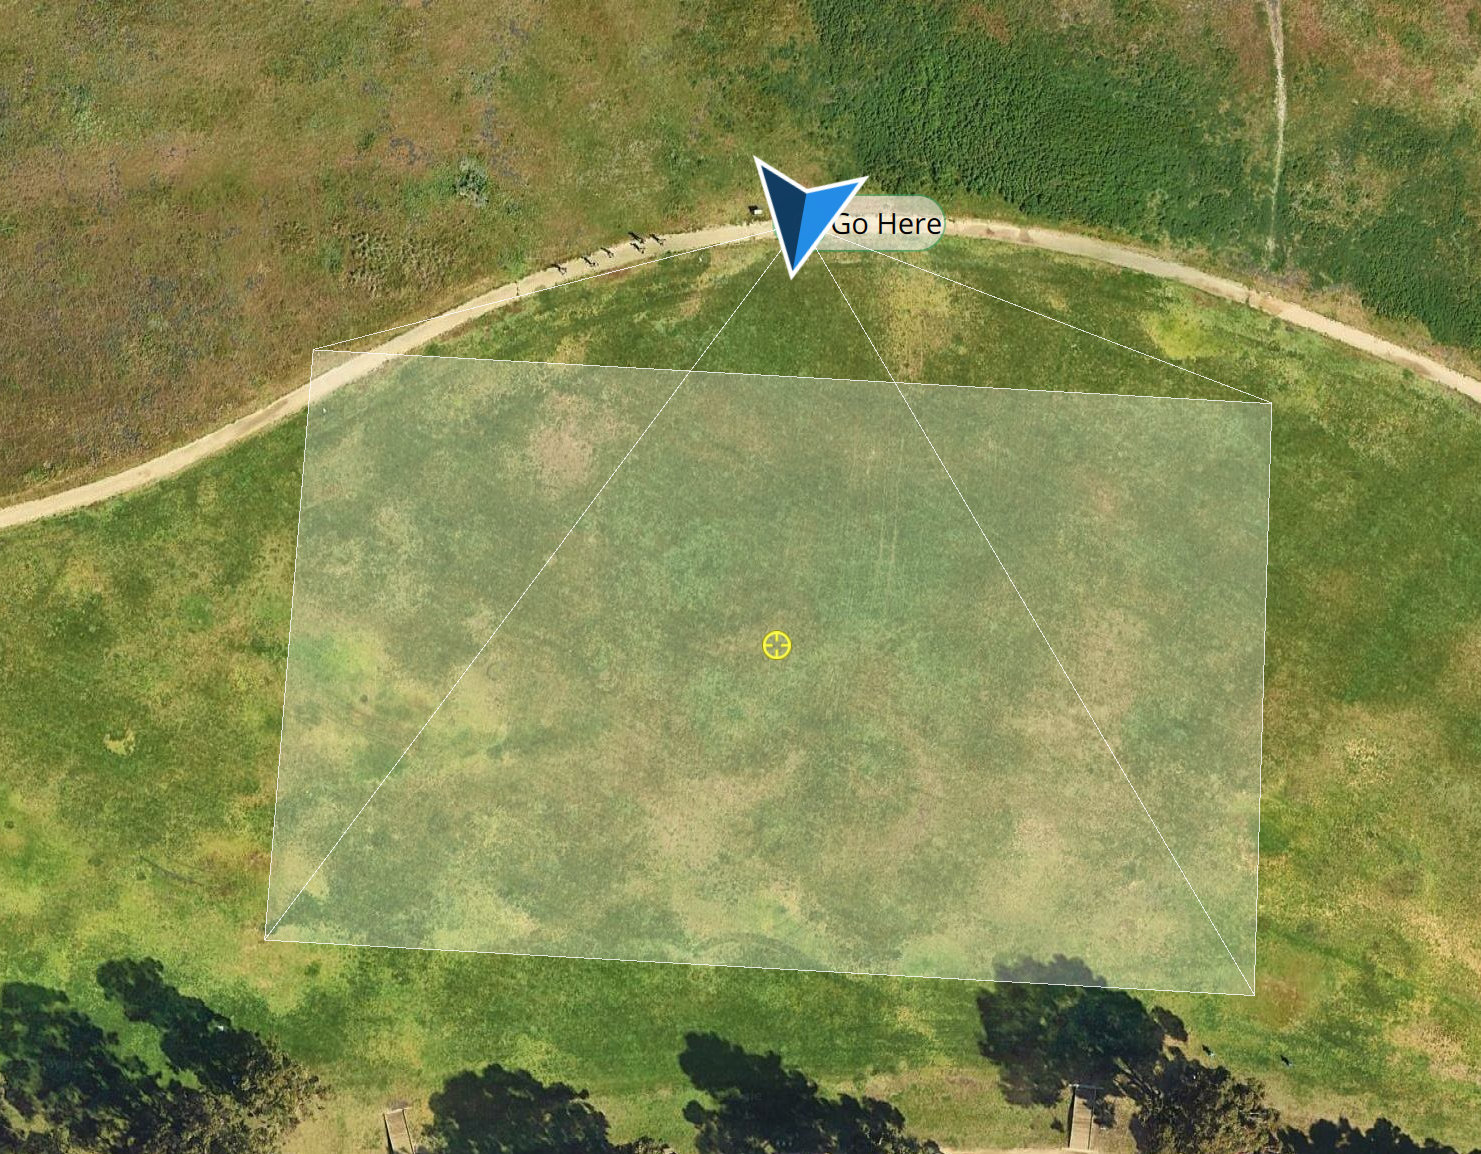
Set **Camera Projection** in the camera settings -> Settings to enabled. This will display a projection of the field of view on the map, with the center of the field of view marked with a yellow marker.
In addition the center field of view coordinates are displayed on the upper edge of the video stream and the map. Selecting the coordinates will freeze them to make reading them easier.
### Figure 8
{% embed url="" %}
For VToLs AMC offers the feature of flying in a figure of 8 to keep a point of interest in the field of vision without hitting the yaw limit of the gimbal. Simply set the 8 on the map, after setting a point of interest the 8 will automatically be realigned to keep the point always in the field of view.
## Supported Versions
| Auterion Mission Control | AuterionOS | TRIP Firmware |
| ------------------------ | ---------- | ---------------------- |
| v2.7.0 | v1.17.0 | v1.3.85/v1.4.8/v1.4.20 |